Dongyoon Hwang

davian_logo          kaistai_logo

Hi! I am a Ph.D. candidate at KAIST AI (DAVIAN Lab), advised by Jaegul Choo.

I am interested in building general-purpose robots that can reliably perceive, reason, and act in the unstructured physical world. My research centers on two directions: (i) grounding robot foundation models in explicit 3D geometry to connect perception with action, and (ii) developing scalable and data-efficient reinforcement learning methods that enable robots to acquire robust control policies through interaction with their environments.

Previously, I was a research intern at Krafton AI and Naver Labs Europe, and received my B.S. in Computer Science from Korea University. In December 2026, I will join Microsoft Research Asia in Tokyo as a research intern.

profile photo

Publications

    Selected  /  All

preprint2026pointmapvla

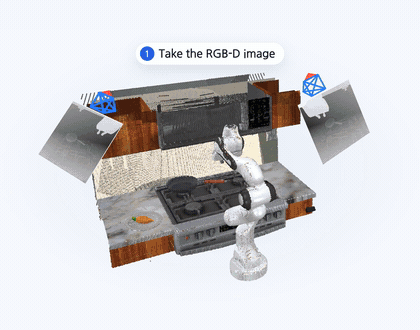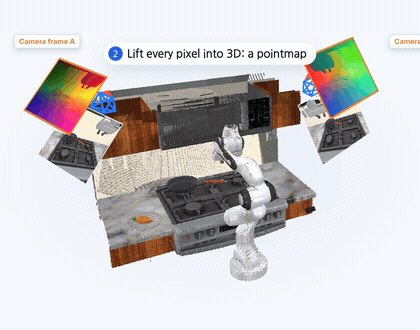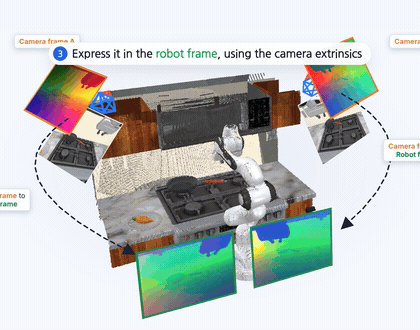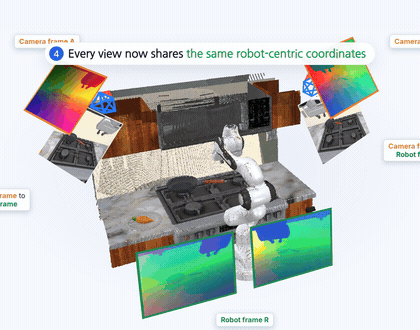
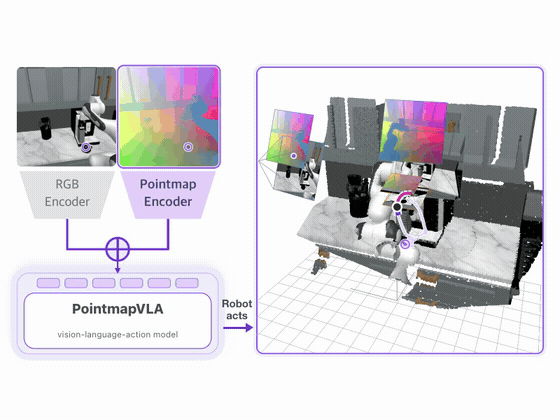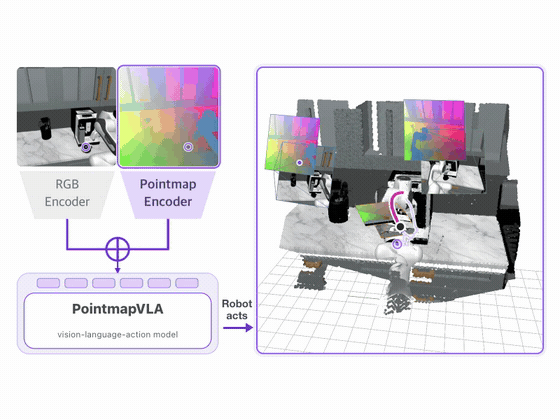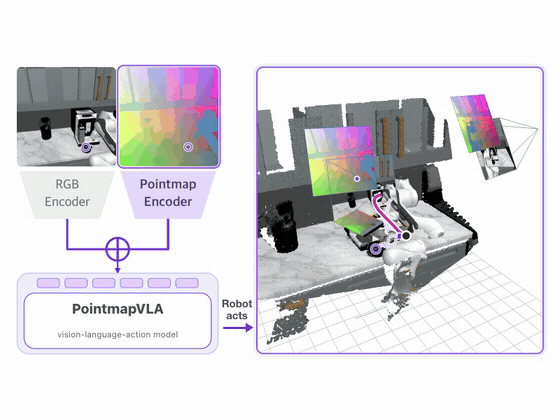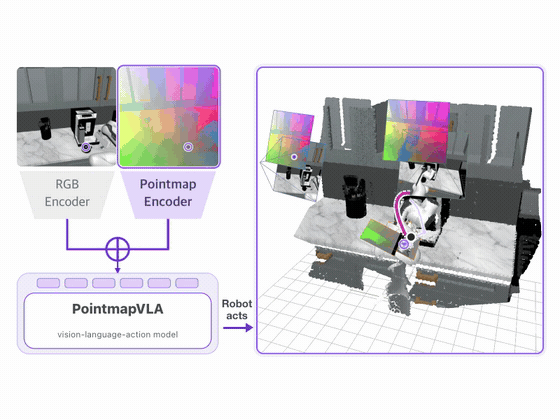
PointmapVLA: Scaling Robot Learning with Robot-Centric Pointmaps
Dongyoon Hwang*, Dongjin Kim*, Byungkun Lee*, Kyungmin Lee, Dohyun Lee, Hojoon Lee, Minho Park, Jaegul Choo. (* Equal contribution)
Preprint'26.
project page / paper / code
preprint2026flashdex

FlashDexRetarget: Accelerating Dexterous Manipulation Data Generation through Multi-Motion Retargeting
Kyungmin Lee*, Sibeen Kim*, Dongyoon Hwang*, Yoonsang Oh*, Donghu Kim, Youngdo Lee, I Made Aswin Nahrendra, Jaegul Choo, Hojoon Lee. (* Equal contribution)
Preprint'26.
project page / arXiv / code
preprint2026pointmap

See like a Robot: Robot-Centric Pointmaps for VLA Models
Byungkun Lee*, Dongyoon Hwang*, Dongjin Kim, Hojoon Lee, Hyunseung Kim, Jaegul Choo, Minho Park. (* Equal contribution)
Preprint'26.
project page / arXiv
corl2026pam

An Agentic Framework for Proactive Robots with Procedural Assistance Memory
Dohyun Lee*, Minho Park*, Jeonghoon Park, Dongyoon Hwang, Junha Hyung, Sungwon Hwang, Byungkun Lee, Jaegul Choo. (* Equal contribution)
CoRL'26.
project page / arXiv / code
corl2026phuma

PHUMA: Physically Reliable Humanoid Locomotion Dataset
Kyungmin Lee*, Sibeen Kim*, Youngdo Lee, Minho Park, Hyunseung Kim, Dongyoon Hwang, Donghu Kim, Hojoon Lee, Jaegul Choo. (* Equal contribution)
CoRL'26, Spotlight.
project page / arXiv / code / dataset
iros2026hamster

3D HAMSTER: Bridging Planning and Control in Hierarchical Vision Language Action Models through 3D Trajectory Guidance
Dongyoon Hwang*, Byungkun Lee*, Dongjin Kim*, Hyojin Jang, Hoiyeong Jin, Jueun Mun, Minho Park, Hojoon Lee, Hyunseung Kim, Jaegul Choo. (* Equal contribution)
IROS'26.
project page / arXiv / code / HF models
colm2025chess

Can Large Language Models Develop Strategic Reasoning? Post-training Insights from Learning Chess
Dongyoon Hwang*, Hojoon Lee*, Jaegul Choo, Dongmin Park, Jongho Park. (* Equal contribution)
CoLM'25, SCALR Workshop.
arXiv
iclr2025simba

SimBa: Simplicity Bias for Scaling Up Parameters in Deep Reinforcement Learning
Hojoon Lee*, Dongyoon Hwang*, Donghu Kim, Hyunseung Kim, Jun Jet Tai, Kaushik Subramanian, Peter R. Wurman, Jaegul Choo, Peter Stone, Takuma Seno. (* Equal contribution)
ICLR'25, Spotlight (top 5%).
project page / arXiv / code
neurips2024dodont

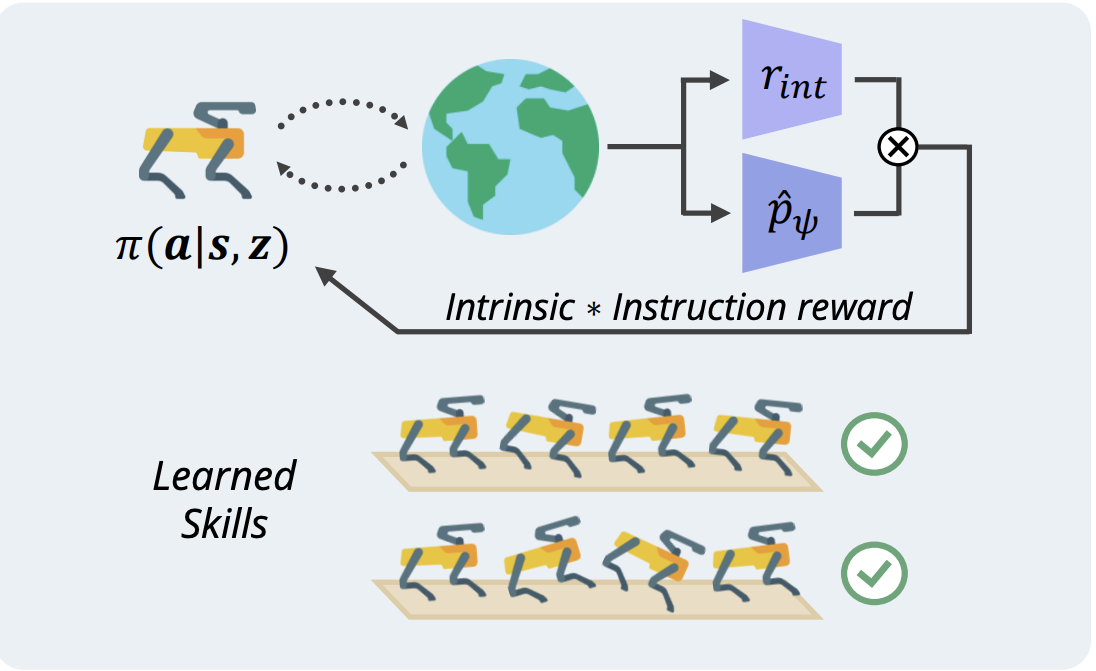
Do’s and Don’ts: Learning Desirable Skills with Instruction Videos
Hyunseung Kim, Byungkun Lee, Hojoon Lee, Dongyoon Hwang, Donghu Kim, Jaegul Choo.
NeurIPS'24.
project page / arXiv
icml2024coin

CoIn: Adapting Pretrained ViTs with Convolution Injector for Visuo-Motor Control
Dongyoon Hwang*, Byungkun Lee*, Hojoon Lee, Hyunseung Kim, Jaegul Choo. (* Equal contribution)
ICML'24.
project page / arXiv / code
icml2024atari-pb

ATARI-PB: Investigating Pre-Training Objectives for Generalization in Vision-Based Reinforcement Learning
Donghu Kim*, Hojoon Lee*, Kyungmin Lee*, Dongyoon Hwang, Jaegul Choo. (* Equal contribution)
ICML'24.
project page / arXiv
tors2024sardine

SARDINE: Simulator for Automated Recommendation in Dynamic and Interactive Environments
Romain Deffayet, Thibaut Thonet, Dongyoon Hwang, Vassilissa Lehoux, Jean-Michel Renders, Maarten de Rijke.
ACM TORS'24.
paper / code
neurips2023disco-dance

DISCO-DANCE: Learning to Discover Skills through Guidance
Hyunseung Kim*, Byungkun Lee*, Hojoon Lee, Dongyoon Hwang, Sejik Park, Kyushik Min, Jaegul Choo. (* Equal contribution)
NeurIPS'23.
project page / arXiv / code / Bibtex
icml2023simtpr

SimTPR: On the Importance of Feature Decorrelation for Unsupervised Representation Learning in Reinforcement Learning
Hojoon Lee, Koanho Lee, Dongyoon Hwang, Hyunho Lee, Byungkun Lee, Jaegul Choo.
ICML'23.
arXiv / code / poster / Bibtex
sigir2022irs

Towards Validating Long-Term User Feedbacks in Interactive Recommendation Systems
Hojoon Lee, Dongyoon Hwang, Kyushik Min, Jaegul Choo.
SIGIR'22 (short), Best Short Paper Honorable Mention.
paper / poster / Bibtex
www2022draftrec

DraftRec: Personalized Draft Recommendation for Winning in Multi-Player Online Battle Arena Games
Hojoon Lee*, Dongyoon Hwang*, Hyunseung Kim, Byungkun Lee, Jaegul Choo. (* Equal contribution)
WWW'22.
arXiv / code / poster / Bibtex
preprint2021moimixer

MOI-Mixer: Improving MLP-Mixer with Multi Order Interactions in Sequential Recommendation
Hojoon Lee, Dongyoon Hwang, Sunghwan Hong, Changyeon Kim, Seungryong Kim, Jaegul Choo.
Preprint'21.
arXiv

Work Experience

Microsoft Research Asia Starting Dec 2026
Research Intern Tokyo, Japan
  • Data-efficient reinforcement learning for real-world adaptation of robot foundation models.
Krafton AI Nov 2024 - Nov 2025
Research Intern Seoul, Korea
  • Built an AI co-playable character (CPC) for PUBG Ally on top of LLM/VLM-based agent systems. demo
  • PUBG Ally debuted at CES 2025 as a joint showcase with NVIDIA and later entered beta in PUBG: BATTLEGROUNDS. news
  • Developed an LLM-based chess-reasoning agent post-trained with reinforcement learning. paper
Naver Labs Europe Nov 2022 - Feb 2023
Research Intern Grenoble, France
  • Studied representation learning for RL-based recommender systems. paper

Other activities

Awards
  • Spotlight Presentation (top 5%), SimBa, ICLR, 2025.
  • Best Short Paper Honorable Mention Award, ACM SIGIR, 2022.
  • Graduation Project Award, Silver Prize ($2,000 as awards), Korea University, 2021.

Template based on Jon Barron's website.